Oumayma Bounou

I’m a postdoctoral researcher at NYU, where I am working with Yann LeCun on world models. Before that, I completed my PhD in the WILLOW project-team which is a joint team between Inria Paris, the Department of Computer Science of Ecole Normale Supérieure, and CNRS, where I was advised by Justin Carpentier and Jean Ponce.
Prior to that, I received an engineering degree from Télécom Paris.
My research interests lie in world models, control and optimization.
news
| Jul 2026 | I was in Seoul for the Global AI Frontier Lab workshop and ICML! |
|---|---|
| May 2026 | I was Gold Reviewer for ICML 2026! |
| Apr 2026 | Our work on temporal straightening for latent space planning was accepted to ICML 2026! |
| Feb 2026 | I attended the World Modeling Workshop in Montréal! |
| Jan 2025 | I joined Yann LeCun’s group at NYU as a postdoc! |
| Dec 2024 | I was in Milan to present our work on learning system dynamics under optimal control guidance at CDC 2024. |
| Oct 2024 | I successfully defended my PhD! |
| Dec 2023 | I was in Singapore to visit Eureka Robotics and to present our work on differentiating optimal control solvers at CDC 2023. |
| Jul 2023 | Our work on differentiating optimal control solvers was accepted to CDC 2023! |
| Jun 2022 | I visited Jean Ponce at the CDS and Ludovic Righetti at the Machines in Motion lab at NYU Tandon. |
| Sep 2021 | Our work on learning representations from videos for control was accepted to NeurIPS 2021! |
| Oct 2020 | I started my PhD in the WILLOW team! |
selected publications
-
-
-
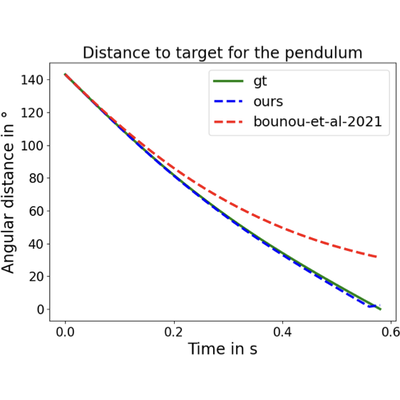 Learning System Dynamics from Sensory Input under Optimal Control PrinciplesIEEE Conference on Decision and Control (CDC) 2024
-
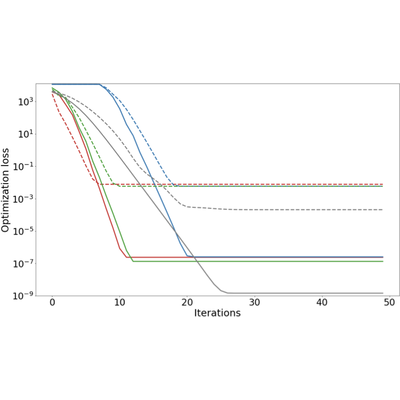 Leveraging Proximal Optimization for Differentiating Optimal Control SolversIEEE Conference on Decision and Control (CDC) 2023
-
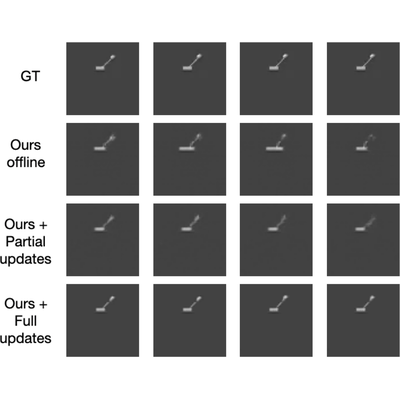 Online Learning and Control of Complex Dynamical Systems from Sensory InputConference on Neural Information Processing Systems (NeurIPS) 2021